Systems of Particles and Rotational Motion
Class 11 Physics · Physics Part I · Chapter 6
163 members in the CBSE community
View all










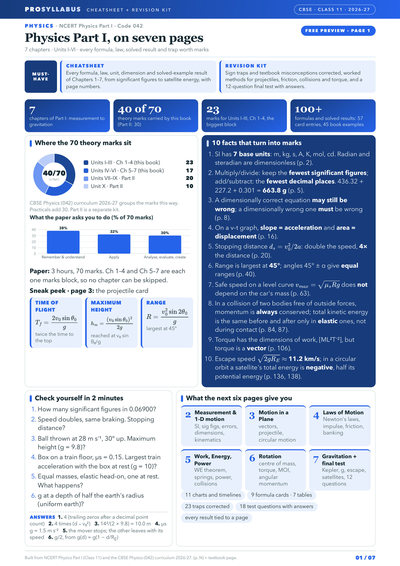
CBSE Class 11 · Physics
Every formula of Ch 1–7, with page numbers- Marks booster + cheatsheet: key concepts in 2 lines each, common traps
- 23-mark block: Ch 1–4
- 17-mark block: Ch 5–7
- Common traps, corrected
- 7 chapters: every solved-example result
- Every unit and dimension, listed
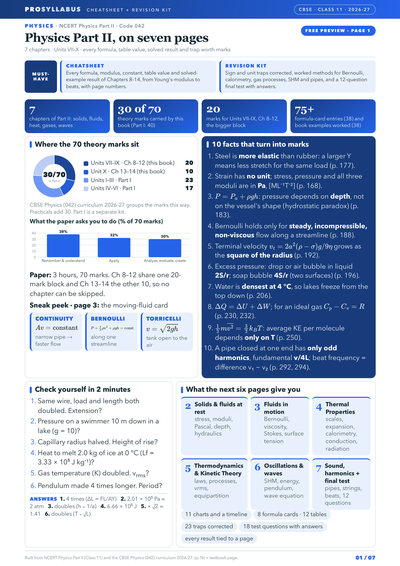
CBSE Class 11 · Physics
Ch 8–14 formulas and table values, by page- Marks booster + cheatsheet: key concepts in 2 lines each, common traps
- 20-mark block: Ch 8–12
- 10-mark block: Oscillations and Waves
- Common traps, corrected
- 7 chapters: every solved-example result
- Sound, standing waves and beats covered
Summary
This chapter extends mechanics from a point particle to extended bodies, especially rigid bodies whose shape does not change. The centre of mass of a system is the mass-weighted average position, and it moves as if all the mass and the total external force were concentrated there, so its motion obeys Newton's laws even when individual particles move complexly. The total linear momentum of a system equals the total mass times the velocity of the centre of mass and is conserved when no external force acts. The vector (cross) product is introduced, leading to the definitions of torque \(\boldsymbol{\tau}=\mathbf{r}\times\mathbf{F}\) and angular momentum \(\mathbf{L}=\mathbf{r}\times\mathbf{p}\); the rotational analogue of Newton's second law is \(\boldsymbol{\tau}=\mathrm{d}\mathbf{L}/\mathrm{d}t\). When the net external torque is zero, angular momentum is conserved. A rigid body is in mechanical equilibrium when both net force and net torque vanish. The moment of inertia \(I=\sum m_ir_i^{2}\) is the rotational analogue of mass, depending on the mass distribution and axis; the radius of gyration and the theorems of perpendicular and parallel axes help compute it. Rotational kinematics mirrors linear kinematics with \(\theta,\omega,\alpha\), rotational kinetic energy is \(\tfrac12 I\omega^{2}\), and \(L=I\omega\) for rotation about a fixed axis.